The hardware and bandwidth for this mirror is donated by dogado GmbH, the Webhosting and Full Service-Cloud Provider. Check out our Wordpress Tutorial.
If you wish to report a bug, or if you are interested in having us mirror your free-software or open-source project, please feel free to contact us at mirror[@]dogado.de.


multiscape is an exact optimisation framework for
multi-action, multi-objective spatial planning in R. It
addresses planning problems in which management actions are explicit
decision alternatives whose spatial allocation must satisfy planning
requirements while accounting for multiple competing objectives.
Building on the transition from place-based prioritisation towards
spatially explicit action planning (Tallis et al., 2021; Salgado-Rojas et al.,
2023), multiscape jointly represents where
management actions can be implemented, which actions are selected, and
the consequences expected from those decisions.
Planning units, features, feasible actions, action-specific costs and outcomes, and spatial or management constraints are represented within a mixed-integer linear programming (MILP) formulation. Multiple objectives are defined independently, allowing ecological, economic, and spatial criteria to remain explicit rather than being collapsed a priori into a single criterion. Alternative spatial plans can then be generated and compared to characterise trade-offs among objectives and the corresponding spatial allocation of management actions. This formulation supports conservation and restoration applications as well as broader multiple-use spatial planning problems involving ecological, economic, and social objectives (Neubert et al., 2025).
Install the released version of multiscape from Comprehensive R
Archive Network (CRAN):
install.packages("multiscape")Alternatively, install the latest development version from GitHub:
if (!requireNamespace("remotes", quietly = TRUE)) {
  install.packages("remotes")
}
remotes::install_github("josesalgr/multiscape")We illustrate the multiscape workflow using a spatial
planning problem from Spain’s Meseta Ibérica, adapted from Cánibe Iglesias et
al. (2025). The example comprises 11,109 planning
units, 151 species, four ecosystem-service
features, and four alternative management actions:
Afforestation, BAU,
FarmReturn, and Firesmart.
Before constructing the optimisation problem, we examine its spatial
units, features, management alternatives, implementation costs, and
expected outcomes. The example data are included in
multiscape and can be loaded directly.
library(multiscape)
meseta <- load_meseta()The study area is divided into 11,109 planning units of approximately
1 km². Each unit represents a location where a
management action may be implemented. The supplied spatial polygons and
identifiers are stored in planning_units.
head(meseta$planning_units)
#> Simple feature collection with 6 features and 2 fields
#> Geometry type: POLYGON
#> Dimension:     XY
#> Bounding box:  xmin: 2936400 ymin: 2279200 xmax: 2945400 ymax: 2281200
#> Projected CRS: GRS_1980_IUGG_1980_Lambert_Azimuthal_Equal_Area
#>   id                       geometry cost
#> 1  1 POLYGON ((2944400 2280200, ...  0.1
#> 2  2 POLYGON ((2945400 2280200, ...  0.1
#> 3  3 POLYGON ((2937400 2279200, ...  0.1
#> 4  4 POLYGON ((2938400 2279200, ...  0.1
#> 5  5 POLYGON ((2939400 2279200, ...  0.1
#> 6 6 POLYGON ((2944400 2279200, ... 0.1The planning problem considers 155 features: 151 species and four
ecosystem services. A feature is a measurable quantity
represented in the planning model. The features table
identifies these quantities, while dist_features provides
their reference amounts by planning unit and feature.
These amounts serve as the comparison values for action-specific
outcomes; they do not define management decisions or representation
targets.
head(meseta$features)
#>   id    name
#> 1  1 ACCGENT
#> 2  2 ACCNISU
#> 3  3 ACRARUN
#> 4  4 ACRSCIR
#> 5  5 AEGCAUD
#> 6  6     AER
In this example, dist_features assigns zero credited
representation to the reference. Representation is instead credited
through the outcomes associated with selected actions.
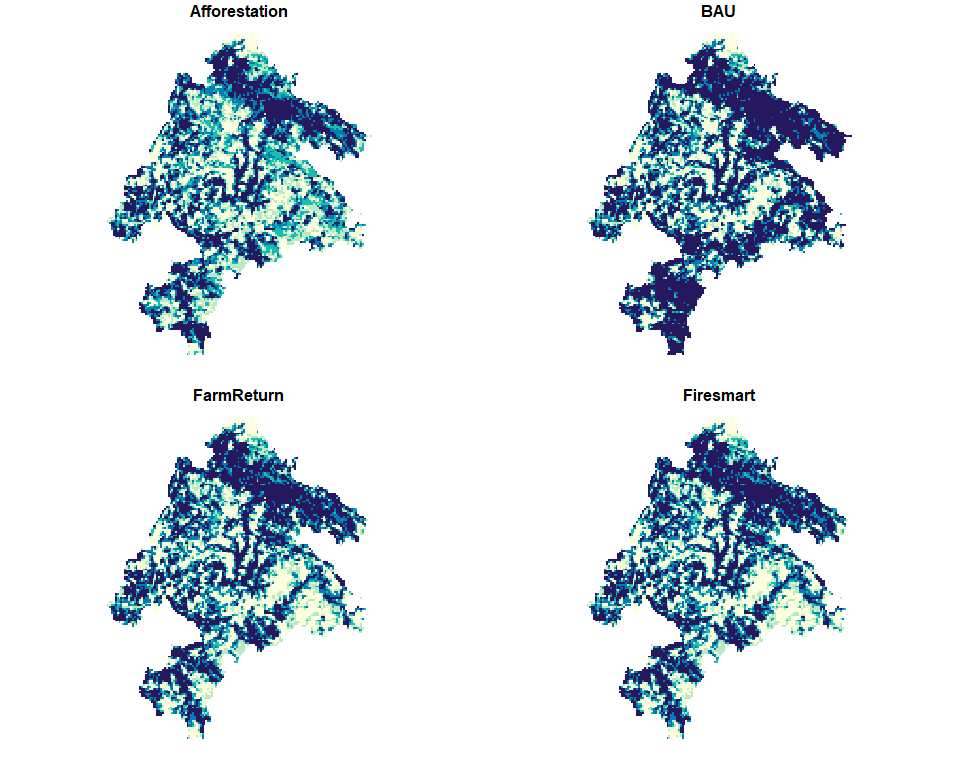
Four alternative actions can be implemented throughout the study area: Afforestation, BAU, FarmReturn, and Firesmart. Their implementation costs vary by planning unit, so a plan’s cost depends on which actions are chosen and where they are implemented.
meseta$actions
#>              id          name
#> 1 Afforestation Afforestation
#> 2           BAU           BAU
#> 3    FarmReturn    FarmReturn
#> 4 Firesmart Firesmartplot(
meseta$maps$costs,
main = "Action-specific implementation costs",
border = NA,
pal = function(n) hcl.colors(n, "YlGnBu", rev = TRUE)
)
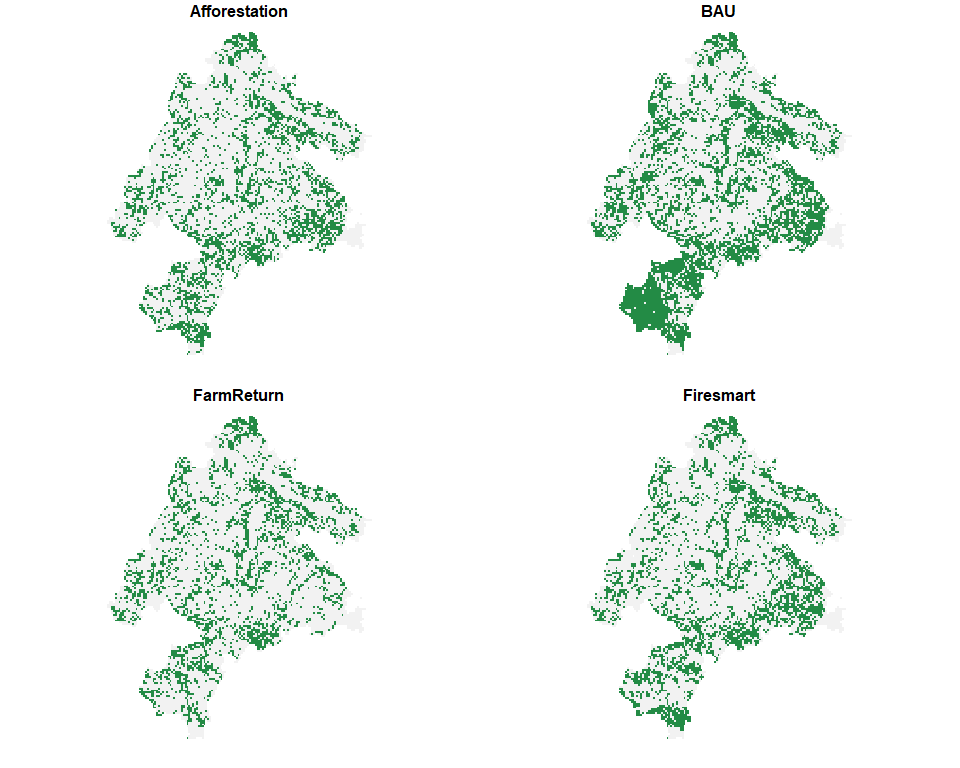
The same feature may respond differently to different management
actions and locations. The outcomes table supplies its
expected representation for each recorded planning-unit, feature, and
action combination. In this dataset, outcomes are binary: a value of 1
credits one unit of representation, while unrecorded combinations
contribute zero. This coding also applies to the included
ecosystem-service features.
head(meseta$outcomes)
#>   pu feature outcome        action
#> 1  1       7       1 Afforestation
#> 2  1       8       1 Afforestation
#> 3  1      12       1 Afforestation
#> 4  1      13       1 Afforestation
#> 5  1      14       1 Afforestation
#> 6  1      15       1 Afforestation
The maps below illustrate the action-specific representation of
DENMINO. They show outcomes, rather than
differences from the reference.
plot(
  meseta$maps$DENMINO,
  main = "Action-specific outcomes for DENMINO",
  border = NA,
  breaks = c(-0.1, 0.5, 1.1),
  pal = function(n) c("grey95", "#238b45")
)
We now use these inputs to build a Problem object. The
stages below first establish its spatial and feature structure, then add
management decisions and their consequences, feasibility requirements,
and objectives. No optimisation is performed until the method and solver
have been configured.
create_problem() defines the planning units, the feature
catalogue, and the reference amounts stored in
dist_features. We pass the supplied tables directly. In
Stage 4, include_pu_cost = FALSE excludes the separate
planning-unit cost from the objective, so this example counts only the
costs of implementing specific actions, which we introduce in Stage
2.
problem <- create_problem(
  pu = meseta$planning_units,
  features = meseta$features,
  dist_features = meseta$dist_features,
  cost = "cost"
)
The initial Problem contains the spatial structure and
155 features, but no registered actions, effects, constraints, or
objectives. This incomplete state is expected: those components are
added in subsequent stages. We can inspect the model as it is being
constructed.
print(problem)
#> A multiscape object (<Problem>)
#> ├─data
#> │├─planning units: <tbl_df> (11109 total)
#> │├─costs: min: 0.1, max: 0.1
#> │└─features: 155 total ("ACCGENT", "ACCNISU", "ACRARUN", ...)
#> └─actions and effects
#> │├─actions: none
#> │├─feasible action pairs: none
#> │├─effect data: none
#> │└─profit data: none
#> └─spatial
#> │├─geometry: sf (11109 rows)
#> │├─coordinates: 11109 rows (x: 2868900..3007900, y: 2110700..2280700)
#> │└─relations: none
#> └─targets and constraints
#> │├─targets: none
#> │├─area constraints: none
#> │├─budget constraints: none
#> │├─planning-unit locks: none
#> │└─action locks: none
#> └─model
#> │├─status: not built yet (will build in solve())
#> │├─objectives: none
#> │├─method: single-objective
#> │├─solver: not set (auto)
#> │└─checks: incomplete (no objective registered)
#> # ℹ Use `x$data` to inspect stored tables and model snapshots.add_actions() registers the available management
decisions and their implementation costs; it does not
choose where to implement them. The loader already uses readable action
names as identifiers consistently across actions,
action_costs, and outcomes, so no preparation
is needed.
problem <- problem |>
  add_actions(
    actions = meseta$actions,
    cost = meseta$action_costs
  )
An outcome describes the amount of a feature under a
particular action; an effect describes its change
relative to the reference. If \(r\)
denotes the reference amount and \(y\)
the action-specific outcome, the signed effect is \(\Delta = y-r\). add_effects()
accepts three equivalent ways of specifying a given action’s
consequences, using one of the following columns:
| Column | Supplied value | Outcome \(y\) | Effect \(\Delta\) |
|---|---|---|---|
outcome |
Amount under the action | outcome |
\(y-r\) |
effect |
Signed absolute change | \(r+\text{effect}\) | effect |
relative_change |
Proportional change \(q\) | \(r(1+q)\) | \(rq\) |
For example, with a reference of 100, an outcome of 130, an effect of
30, and a relative change of 0.30 all describe the same resulting
amount. They are alternative inputs, not values to
supply together. When the reference is zero, proportional changes cannot
produce a positive outcome; this example therefore uses the supplied
outcome values directly.
problem <- problem |>
  add_effects(
    effects = meseta$outcomes
  )
At this point, the problem describes both the available spatial decisions and the consequences expected if they are implemented. The next stage determines which combinations of decisions are admissible.
Constraints define the feasible set of spatial
plans. We require at most one action per planning unit and impose an
absolute representation target for each feature.
sense = "max" makes the action-cardinality constraint an
upper bound, so units may remain without a selected action. The feature
targets require the sum of credited representation to reach the supplied
minimum for each feature.
head(meseta$targets)
#>   feature target
#> 1       1   92.8
#> 2       2  109.6
#> 3       3   26.4
#> 4       4  180.0
#> 5       5  102.4
#> 6       6  269.6

problem <- problem |>
  add_constraint_action_cardinality(count = 1, sense = "max") |>
  add_constraint_targets_absolute(meseta$targets)
These targets are expressed in the outcome units rather than as percentages of the reference. Given the binary coding of this example, a fractional target must still be met or exceeded by the resulting total representation.
Constraints determine whether a plan is feasible; objectives determine how feasible plans are evaluated. Here we register two quantities to minimise: the cost of implementing the chosen actions and their spatial fragmentation. They remain separate objectives until an optimisation method specifies how to combine them.
problem <- problem |>
  add_spatial_relations(meseta$boundary, name = "boundary") |>
  add_objective_min_cost(include_pu_cost = FALSE, alias = "cost") |>
  add_objective_min_fragmentation_action(
    relation_name = "boundary", alias = "spatial"
  )
The fragmentation objective sums weighted boundaries where the
selection of a given action differs between neighbouring units. Matching
action assignments contribute no boundary for that action; different
actions contribute to their respective boundaries. Minimising this
criterion favours more cohesive action patches without imposing strict
connectivity. The supplied boundary table provides the
spatial relations and their weights.
The optimisation method specifies how registered objectives are handled. For a first illustrative run, we use a weighted sum with coefficients 1 for cost and 0.5 for fragmentation, minimising \(\text{cost}+0.5\,\text{spatial}\). Because weight normalisation and objective scaling are disabled, this choice is sensitive to the input units and should be understood as an illustrative preference, not a universally meaningful trade-off rate.
We save the formulation before configuring the method so that it can also be used for the multi-run exploration below.
problem <- problem |>
  set_method_weighted_sum(
  aliases = c("cost", "spatial"),
  runs = set_runs_manual(data.frame(
    weight_cost = 1,
    weight_spatial = 0.5
  )),
  normalize_weights = FALSE,
  objective_scaling = FALSE
)
The solver then searches for a feasible assignment that minimises the weighted criterion. We use Gurobi, which requires a valid installation and licence, with a 300-second solver limit and a 5% relative optimality-gap limit. Building the optimisation model can require additional time and memory. The optimisation is executed when knitting this README and its result is cached, so subsequent renders need not repeat the solve unless the code changes. Rendering this chunk requires an installed and licensed Gurobi solver.
problem <- set_solver_gurobi(
  problem,
  gap_limit = 0.05,
  time_limit = 300,
  verbose = TRUE
)

solutions <- solve(problem)
#> Set parameter Username
#> Set parameter LicenseID to value 2844238
#> Set parameter TimeLimit to value 300
#> Set parameter FeasibilityTol to value 1e-09
#> Set parameter IntFeasTol to value 1e-09
#> Set parameter MIPGap to value 0.05
#> Set parameter MIPGapAbs to value 0
#> Set parameter OptimalityTol to value 1e-09
#> Set parameter NodefileStart to value 0.5
#> Academic license - for non-commercial use only - expires 2027-07-14
#> Gurobi Optimizer version 12.0.2 build v12.0.2rc0 (win64 - Windows 10.0 (19045.2))
#>
#> CPU model: 12th Gen Intel(R) Core(TM) i7-12700H, instruction set [SSE2|AVX|AVX2]
#> Thread count: 14 physical cores, 20 logical processors, using up to 20 threads
#>
#> Non-default parameters:
#> TimeLimit  300
#> FeasibilityTol  1e-09
#> IntFeasTol  1e-09
#> MIPGap  0.05
#> MIPGapAbs  0
#> OptimalityTol  1e-09
#> NodefileStart  0.5
#> LogToConsole  0
#>
#> Optimize a model with 327122 rows, 142317 columns and 2120102 nonzeros
#> Model fingerprint: 0x18f5272c
#> Variable types: 86772 continuous, 55545 integer (55545 binary)
#> Coefficient statistics:
#>   Matrix range     [1e+00, 1e+00]
#>   Objective range  [1e+00, 7e+00]
#>   Bounds range     [1e+00, 1e+00]
#>   RHS range        [8e-01, 9e+03]
#> Presolve removed 142334 rows and 11125 columns
#> Presolve time: 4.78s
#> Presolved: 184788 rows, 131192 columns, 1681755 nonzeros
#> Variable types: 0 continuous, 131192 integer (131192 binary)
#> Deterministic concurrent LP optimizer: primal simplex, dual simplex, and barrier
#> Showing barrier log only...
#>
#> Root barrier log...
#>
#> Ordering time: 1.96s
#>
#> Barrier statistics:
#>  AA' NZ     : 5.943e+06
#>  Factor NZ  : 2.145e+07 (roughly 300 MB of memory)
#>  Factor Ops : 4.108e+09 (less than 1 second per iteration)
#>  Threads    : 11
#>
#>                   Objective                Residual
#> Iter       Primal          Dual         Primal    Dual     Compl     Time
#>    0   9.08549505e+07 -4.09748130e+05  2.40e+03 0.00e+00  2.36e+03     9s
#>    1   3.47762789e+07 -3.33400318e+05  8.66e+02 1.58e+00  7.33e+02    10s
#>    2   2.81132534e+06 -3.21967467e+05  8.05e+01 8.14e-01  6.08e+01    10s
#>    3   9.02184971e+05 -3.10629553e+05  2.45e+01 4.03e-01  1.91e+01    10s
#>    4   3.87322807e+05 -3.01982316e+05  9.29e+00 2.60e-01  7.71e+00    11s
#>    5   2.24942854e+05 -2.87930717e+05  4.49e+00 1.95e-01  4.08e+00    11s
#>    6   1.21722132e+05 -1.57332447e+05  1.92e+00 7.83e-05  1.43e+00    11s
#>    7   6.70445867e+04 -6.98603867e+04  5.85e-01 5.77e-15  4.66e-01    11s
#>    8   5.56541059e+04 -4.10644675e+04  3.67e-01 6.00e-15  2.90e-01    12s
#>    9   4.25341831e+04 -1.91292600e+04  1.67e-01 4.00e-15  1.60e-01    12s
#>   10   4.16902051e+04 -4.30829840e+03  1.59e-01 6.88e-15  1.17e-01    12s
#>   11   3.81011615e+04  9.81693227e+03  1.10e-01 3.66e-15  6.78e-02    13s
#>   12   3.33141639e+04  1.82504425e+04  5.66e-02 5.66e-15  3.44e-02    13s
#>   13   2.98016261e+04  2.19762987e+04  2.47e-02 7.69e-15  1.75e-02    13s
#>   14   2.88989373e+04  2.25255123e+04  1.84e-02 5.19e-15  1.42e-02    14s
#>   15   2.87336352e+04  2.36594964e+04  1.73e-02 4.00e-15  1.12e-02    14s
#>   16   2.76331951e+04  2.42516480e+04  1.04e-02 4.88e-15  7.48e-03    14s
#>   17   2.70453799e+04  2.45937589e+04  7.05e-03 5.50e-15  5.42e-03    14s
#>   18   2.65020957e+04  2.48596222e+04  4.22e-03 6.95e-15  3.63e-03    15s
#>   19   2.60274969e+04  2.52286068e+04  2.04e-03 4.52e-15  1.76e-03    15s
#>   20   2.58833211e+04  2.53155146e+04  1.48e-03 2.53e-15  1.25e-03    15s
#>   21   2.58179479e+04  2.53643921e+04  1.23e-03 4.88e-15  9.99e-04    16s
#>   22   2.57076401e+04  2.53843108e+04  8.25e-04 5.25e-15  7.13e-04    16s
#>   23   2.56171574e+04  2.54040800e+04  5.03e-04 8.76e-15  4.70e-04    16s
#>   24   2.55623126e+04  2.54257984e+04  3.11e-04 3.61e-15  3.01e-04    16s
#>   25   2.55186149e+04  2.54374382e+04  1.62e-04 3.58e-15  1.80e-04    17s
#>   26   2.54990910e+04  2.54513899e+04  9.99e-05 5.54e-15  1.05e-04    17s
#>   27   2.54875587e+04  2.54560979e+04  6.55e-05 4.63e-15  6.95e-05    17s
#>   28   2.54839890e+04  2.54580283e+04  5.50e-05 2.09e-15  5.74e-05    17s
#>   29   2.54810141e+04  2.54597586e+04  4.59e-05 5.38e-15  4.70e-05    18s
#>   30   2.54729208e+04  2.54612117e+04  2.15e-05 2.33e-15  2.59e-05    18s
#>   31   2.54703240e+04  2.54632141e+04  1.42e-05 3.87e-15  1.57e-05    18s
#>   32   2.54691539e+04  2.54640654e+04  1.09e-05 3.95e-15  1.12e-05    18s
#>   33   2.54659252e+04  2.54641982e+04  1.95e-06 6.77e-15  3.84e-06    19s
#>   34   2.54651950e+04  2.54648110e+04  1.66e-07 5.91e-15  8.56e-07    19s
#>   35   2.54651237e+04  2.54650654e+04  5.57e-08 4.41e-15  1.30e-07    19s
#>   36   2.54650851e+04  2.54650770e+04  3.69e-09 5.87e-15  1.79e-08    20s
#>   37   2.54650823e+04  2.54650821e+04  1.51e-10 1.23e-12  4.88e-10    20s
#>
#> Barrier solved model in 37 iterations and 19.82 seconds (18.67 work units)
#> Optimal objective 2.54650823e+04
#>
#>
#> Root crossover log...
#>
#>   165733 DPushes remaining with DInf 0.0000000e+00                20s
#>        0 DPushes remaining with DInf 0.0000000e+00                23s
#>
#>    22178 PPushes remaining with PInf 8.2450785e-06                23s
#>        0 PPushes remaining with PInf 0.0000000e+00                24s
#>
#>   Push phase complete: Pinf 0.0000000e+00, Dinf 2.7618265e+03     24s
#>
#>
#> Root simplex log...
#>
#> Iteration    Objective       Primal Inf.    Dual Inf.      Time
#>   174690    2.5465082e+04   0.000000e+00   2.761826e+03     24s
#>   175374    2.5465082e+04   0.000000e+00   0.000000e+00     25s
#> Concurrent spin time: 0.00s
#>
#> Solved with barrier
#>
#> Root relaxation: objective 2.546508e+04, 175374 iterations, 19.20 seconds (13.70 work units)
#> Total elapsed time = 25.66s (DegenMoves)
#>
#>     Nodes    |    Current Node    |     Objective Bounds      |     Work
#>  Expl Unexpl |  Obj  Depth IntInf | Incumbent    BestBd   Gap | It/Node Time
#>
#>      0     0 25465.0822    0 2133          - 25465.0822      -     -   26s
#> H    0     0                    25633.000000 25465.0822  0.66%     -   27s
#>
#> Explored 1 nodes (182306 simplex iterations) in 27.04 seconds (26.90 work units)
#> Thread count was 20 (of 20 available processors)
#>
#> Solution count 1: 25633
#>
#> Optimal solution found (tolerance 5.00e-02)
#> Best objective 2.563300000000e+04, best bound 2.546550000000e+04, gap 0.6535%
We inspect the returned SolutionSet before analysing its
objective values. The print method summarises the method, attempted
runs, stored solutions, and solver diagnostics.
print(solutions)
#> A multiscape solution set (<SolutionSet>)
#> ├─method
#> │├─name: `weighted`
#> │├─objectives: 2 (cost, spatial)
#> │└─run design: manual
#> │ └─design detail: 1 requested runs
#> └─content
#> │├─design rows: 1
#> │├─attempted runs: 1
#> │├─stored solutions: 1
#> │└─without solution: 0
#> └─run summary
#> │├─statuses: optimal: 1
#> │├─runtime: 27.217
#> │├─gap: 0.0065
#> │├─design columns: none
#> │└─objective columns: value_cost, value_spatial
#> └─objective ranges
#> │├─cost: 23980
#> │└─spatial: 3306
#> # ℹ Use get_runs(), get_objectives(), get_pu(), and get_actions() to inspect
#> results.
A 5% gap is a stopping tolerance, not a guarantee that the exact optimum or a unique spatial plan has been found. Check the reported solver status and gap before interpreting any returned solutions.
The following analyses use the solutions object from
Stage 5. The first results concern a single weighted run; we then vary
the weight on spatial fragmentation to examine alternative plans.
get_runs() links the requested run to the retained
solution and reports its solver status, runtime, and gap.
get_objectives() provides the component objective values in
their original units. The weighted value of this run can be
reconstructed using the same coefficients as above.
get_runs(solutions)
#>   run_id solution_id  status runtime         gap
#> 1      1           1 optimal  27.217 0.006534545

performance <- get_objectives(solutions, format = "wide")

performance
#>   solution_id  cost spatial
#> 1           1 23980    3306
Solver versions and stopping conditions can lead to different feasible plans. Interpret the values returned by your run rather than expecting a particular spatial solution.
Targets express the required feature representation and should be
checked independently of cost and fragmentation.
get_targets() reports the required and achieved amounts for
each feature, allowing all targets to be checked.
target_achievement <- get_targets(solutions)

head(target_achievement)
#>   solution_id feature feature_name target_level total_available target achieved
#> 1           1       1      ACCGENT         92.8              NA   92.8     2384
#> 2           1       2      ACCNISU        109.6              NA  109.6     2636
#> 3           1       3      ACRARUN         26.4              NA   26.4      572
#> 4           1       4      ACRSCIR        180.0              NA  180.0     1068
#> 5           1       5      AEGCAUD        102.4              NA  102.4      103
#> 6           1       6          AER        269.6              NA  269.6      270
#>      gap  met
#> 1 2291.2 TRUE
#> 2 2526.4 TRUE
#> 3  545.6 TRUE
#> 4  888.0 TRUE
#> 5    0.6 TRUE
#> 6    0.4 TRUE

all(target_achievement$met)
#> [1] TRUE
A value of TRUE in the final check indicates that all
reported targets were met. Confirm that the solver returned a feasible
solution before interpreting target achievement.
Objective values describe a plan’s performance; its decision
space representation records which action was assigned to each
planning unit. get_actions() returns the action-level
results, including a selected indicator. Rather than
plotting all 11,109 units, we display the first ten selected assignments
and the number of units assigned to each action.
selected_actions <- get_actions(solutions, solution = 1)

selected_actions <- selected_actions[
  selected_actions$selected == 1,
  c("pu", "action", "cost"),
  drop = FALSE
]

head(selected_actions, 10)
#>    pu action cost
#> 2   1    BAU    1
#> 6   2    BAU    1
#> 10  3    BAU    1
#> 14  4    BAU    1
#> 18  5    BAU    1
#> 22  6    BAU    1
#> 26  7    BAU    1
#> 30  8    BAU    1
#> 34  9    BAU    1
#> 38 10    BAU    1

table(selected_actions$action)
#>
#> Afforestation           BAU    FarmReturn     Firesmart
#>          2363          2719           423          3185
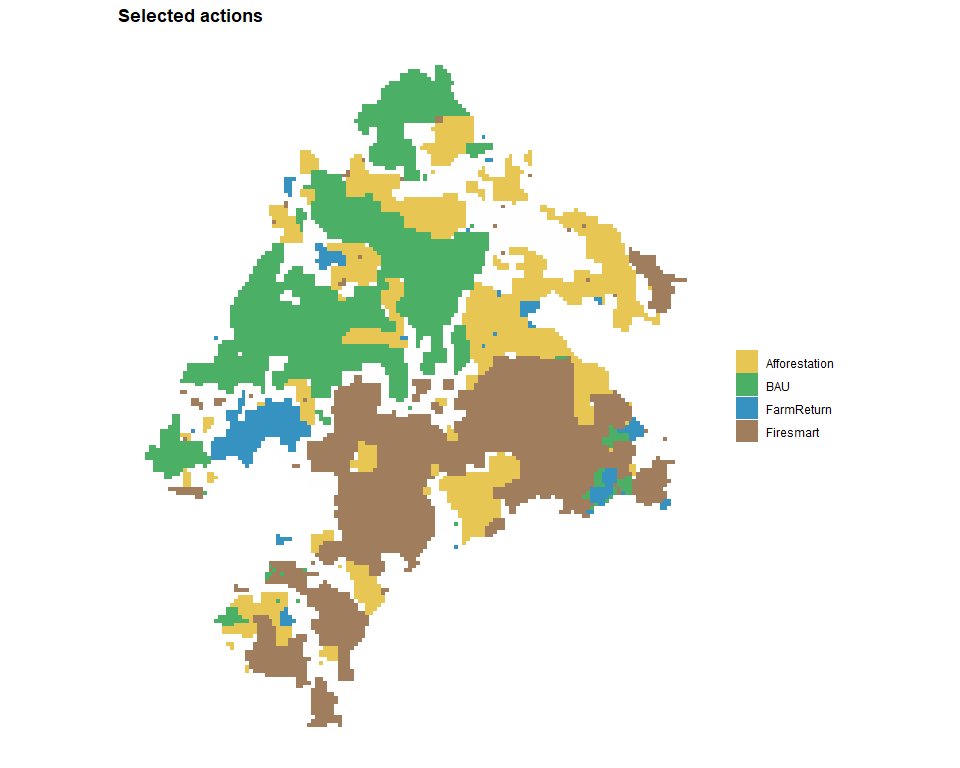
The selected actions can also be inspected spatially.
plot_spatial_actions() shows the complete spatial
prescription for the first solution. Each colour identifies the selected
management action, while grey planning units have no selected action. At
most one action can be selected per planning unit.
plot_spatial_actions(
    solutions,
    solutions = 1,
    layout = "single",
    fill_values = c(
      Afforestation = "#E6C34A",
      BAU = "#41AB5D",
      FarmReturn = "#2B8CBE",
      Firesmart = "#9B7653"
  )
)
To examine the compromise between cost and spatial cohesion, we keep
the planning data and constraints fixed and vary the weight on
fragmentation. We rebuild the same formulation in problemMO
to keep this exploration independent of the preceding single-run
problem. Each row in set_runs_manual() represents one
run.
problemMO <- create_problem(
    pu = meseta$planning_units,
    features = meseta$features,
    dist_features = meseta$dist_features,
    cost = "cost"
  ) |>
    add_actions(
    actions = meseta$actions,
    cost = meseta$action_costs
  ) |>
    add_effects(
    effects = meseta$outcomes
  ) |>
  add_constraint_action_cardinality(count = 1, sense = "max") |>
  add_constraint_targets_absolute(meseta$targets) |>
  add_spatial_relations(meseta$boundary, name = "boundary") |>
  add_objective_min_cost(include_pu_cost = FALSE, alias = "cost") |>
  add_objective_min_fragmentation_action(
    relation_name = "boundary", alias = "spatial"
  ) |>
  set_solver_gurobi(
    gap_limit = 0.05,
    time_limit = 300,
    verbose = FALSE
  )

spatial_weights <- c(0, 0.1, 0.25, 0.5, 1, 2)

spatial_exploration <- problemMO |>
  set_method_weighted_sum(
  aliases = c("cost", "spatial"),
  runs = set_runs_manual(data.frame(
    weight_cost = 1,
    weight_spatial = spatial_weights
  )),
  normalize_weights = FALSE,
  objective_scaling = FALSE
)

alternatives <- solve(spatial_exploration)
The objective values of the six solutions can be inspected directly
with get_objectives() and visualised using
plot_tradeoff().
get_objectives(alternatives, format = "wide")
#>   solution_id  cost spatial
#> 1           1 22637   22485
#> 2           2 22765    7865
#> 3           3 23173    5231
#> 4           4 23980    3306
#> 5           5 24944    1822
#> 6           6 25996    1090

plot_tradeoff(
    alternatives,
    label_runs = TRUE,
    objectives = c("cost", "spatial"),
    connect = FALSE
)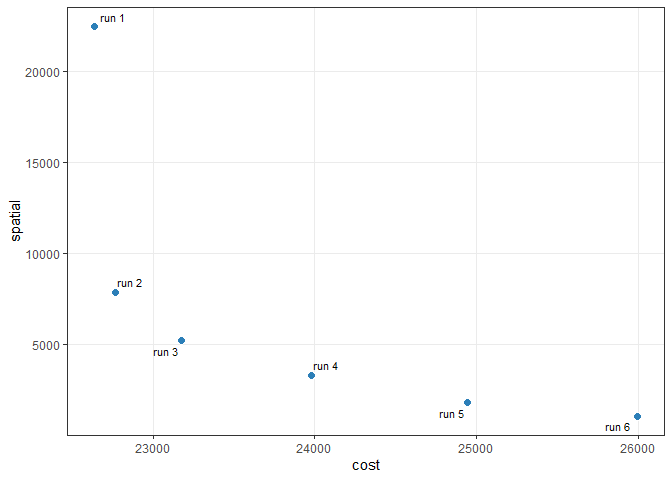
Both objectives are minimised, so smaller values are preferred on either axis. A larger spatial coefficient gives the solver a stronger incentive to accept higher costs if this reduces fragmentation. These six weighted runs sample the trade-off: they do not establish its complete Pareto frontier.
The returned objective values show the observed compromises directly: a lower fragmentation score may require a higher implementation cost, while a cost-focused run may produce a more fragmented assignment. Because the solver stops at a finite optimality gap, the sample can include dominated solutions. Subsequent frontier diagnostics describe the observed set, not a complete Pareto frontier.
The trade-off plot summarises how the objectives change, but not which management actions are selected in each location. We therefore map the spatial assignments in the six retained alternatives, using consistent colours across panels. Grey planning units have no selected action.
plot_spatial_actions(
    alternatives,
    solutions = get_objectives(alternatives, format = "wide")$solution_id,
    layout = "single",
    ncol = 2,
    fill_values = c(
      Afforestation = "#E6C34A",
      BAU = "#41AB5D",
      FarmReturn = "#2B8CBE",
      Firesmart = "#9B7653"
    )
)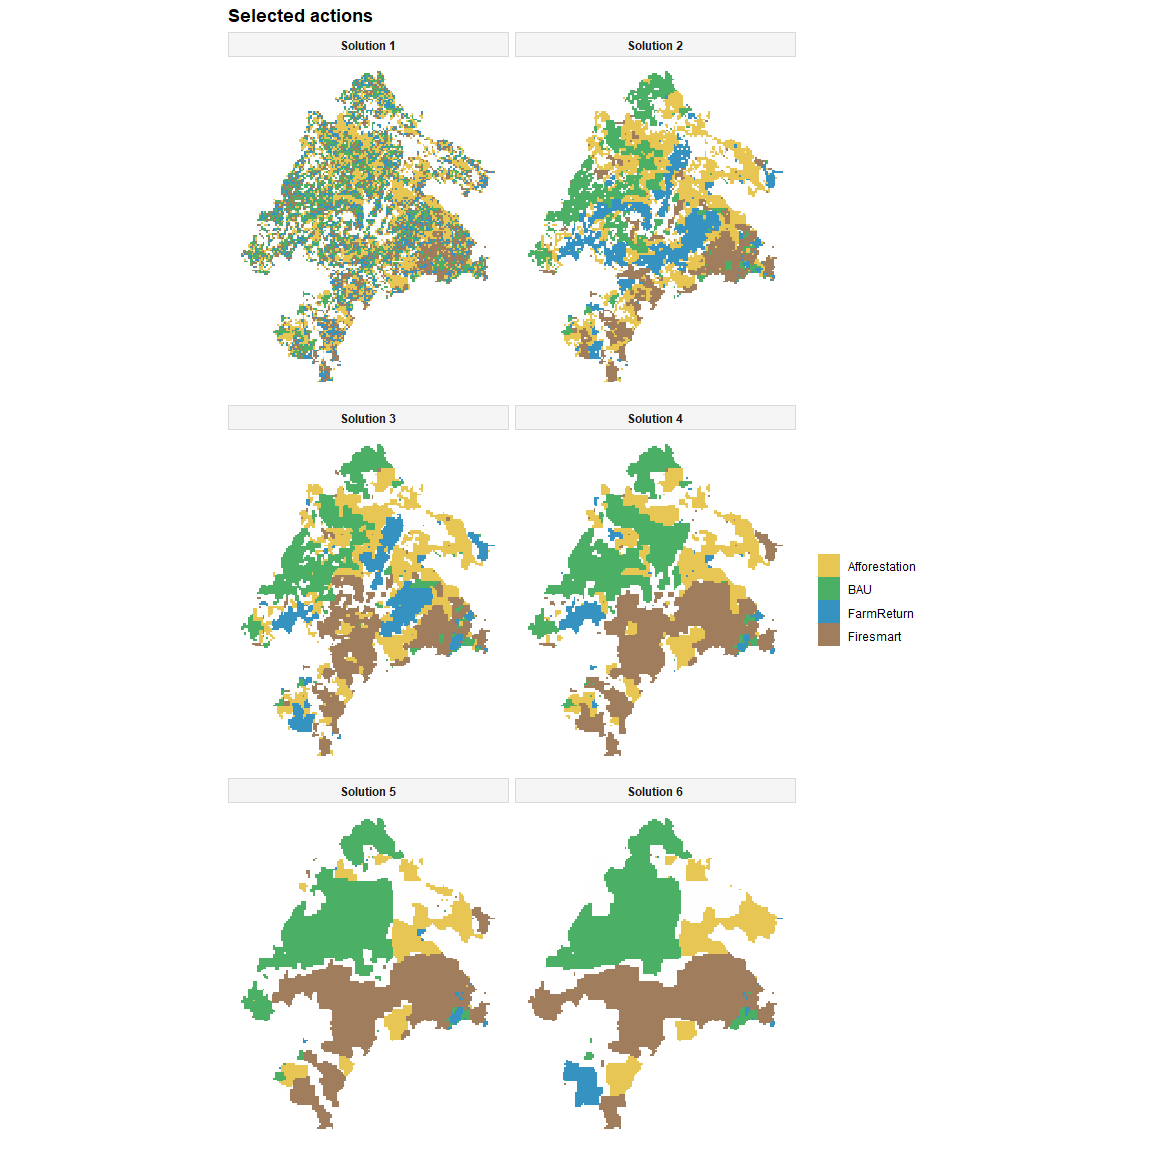
These panels illustrate how increasing the fragmentation weight changes the location and composition of selected actions. They show solutions for the bundled inputs, rather than the ten-replicate scenario analysis in the original study.
Objective values reveal performance, but do not show how similar two spatial prescriptions are. In decision space, Jaccard similarity measures overlap in selected planning unit-action pairs. A value of 1 means identical assignments; 0 means no assignments in common.
selection_similarity(alternatives, metric = "jaccard", format = "matrix")
#>           1         2         3         4         5         6
#> 1 1.0000000 0.3256152 0.2932796 0.2495680 0.2002491 0.1745742
#> 2 0.3256152 1.0000000 0.6390935 0.4364974 0.2988033 0.2468110
#> 3 0.2932796 0.6390935 1.0000000 0.5766297 0.4054251 0.3430646
#> 4 0.2495680 0.4364974 0.5766297 1.0000000 0.6582665 0.5065351
#> 5 0.2002491 0.2988033 0.4054251 0.6582665 1.0000000 0.7065921
#> 6 0.1745742 0.2468110 0.3430646 0.5065351 0.7065921 1.0000000
#> attr(,"metric")
#> [1] "jaccard"

action_frequency <- selection_frequency(alternatives)
head(action_frequency[order(-action_frequency$frequency), ], 10)
#>        pu        action n_selected n_solutions frequency
#> 80  10014     Firesmart          6           6         1
#> 82  10015           BAU          6           6         1
#> 145  1003 Afforestation          6           6         1
#> 185 10039 Afforestation          6           6         1
#> 193 10040 Afforestation          6           6         1
#> 197 10041 Afforestation          6           6         1
#> 204 10042     Firesmart          6           6         1
#> 214 10045           BAU          6           6         1
#> 317 10069 Afforestation          6           6         1
#> 325 10070 Afforestation          6           6         1
Assignment frequency measures recurrence within the six retained plans, not an ecological selection probability or irreplaceability measure.
An observed solution is dominated when another
observed solution is no worse on either objective and better on at least
one. frontier_knee() identifies a potential compromise
among the observed non-dominated solutions. Its result depends on the
sampled objective values and their normalisation, so it should be
treated as a decision aid rather than a uniquely best plan.
frontier_extremes() and frontier_distances()
provide additional diagnostics relative to the observed extreme, ideal,
and nadir values.
# Which observed solution offers an empirical compromise?
knee <- frontier_knee(alternatives, objectives = c("cost", "spatial"))
knee[, c("solution_id", "cost", "spatial", "knee_score"), drop = FALSE]
#>   solution_id  cost spatial knee_score
#> 1           3 23173    5231  0.4574124

# Best and worst observed values for each objective.
frontier_extremes(alternatives, objectives = c("cost", "spatial"))
#>   solution_id objective sense bound  role value
#> 1           1      cost   min   min  best 22637
#> 2           6      cost   min   max worst 25996
#> 3           6   spatial   min   min  best  1090
#> 4           1   spatial   min   max worst 22485

# Distance and ranking relative to the empirical ideal and nadir.
distances <- frontier_distances(
  alternatives,
  objectives = c("cost", "spatial"),
  reference = c("ideal", "nadir")
)
distances[, c(
  "solution_id", "distance_to_ideal", "rank_to_ideal",
  "distance_to_nadir", "rank_from_nadir"
), drop = FALSE]
#>   solution_id distance_to_ideal rank_to_ideal distance_to_nadir rank_from_nadir
#> 1           1         1.0000000             5          1.000000               5
#> 2           2         0.3189474             2          1.179910               1
#> 3           3         0.2508477             1          1.164767               2
#> 4           4         0.4130194             3          1.078791               3
#> 5           5         0.6876632             4          1.015298               4
#> 6 6 1.0000000 5 1.000000 5Linkage analysis asks whether changes in objective
performance correspond to small adjustments or substantial
reconfigurations of selected actions. frontier_neighbors()
identifies neighbouring solutions in objective space;
linkage_distances() and linkage_turnover()
relate performance differences to distances or changes in their spatial
assignments.
neighbors <- frontier_neighbors(
  alternatives, objectives = c("cost", "spatial")
)

linkage <- linkage_distances(
  alternatives,
  objectives = c("cost", "spatial"),
  pairs = neighbors,
  decision_metric = "jaccard"
)
linkage[, c(
  "from_solution", "to_solution",
  "objective_distance", "decision_distance"
), drop = FALSE]
#>   from_solution to_solution objective_distance decision_distance
#> 1             6           5          0.3150517         0.2934079
#> 2             5           4          0.2952532         0.3417335
#> 3             4           3          0.2565453         0.4233703
#> 4             3           2          0.1729464         0.3609065
#> 5             2           1          0.6843989         0.6743848

turnover <- linkage_turnover(
  alternatives,
  objectives = c("cost", "spatial"),
  pairs = neighbors,
  decision_metric = "jaccard"
)
turnover[, c(
  "from_solution", "to_solution", "objective_distance",
  "decision_distance", "reconfiguration_rate"
), drop = FALSE]
#>   from_solution to_solution objective_distance decision_distance
#> 1             6           5          0.3150517         0.2934079
#> 2             5           4          0.2952532         0.3417335
#> 3             4           3          0.2565453         0.4233703
#> 4             3           2          0.1729464         0.3609065
#> 5             2           1          0.6843989         0.6743848
#>   reconfiguration_rate
#> 1            0.9313008
#> 2            1.1574252
#> 3            1.6502751
#> 4            2.0868113
#> 5            0.9853681
linkage_contrasts() identifies the pairs with the
greatest reconfiguration relative to their objective-space separation.
linkage_transition() shows which assignments changed
between a selected pair of solutions, and
selection_consistency() summarises recurring planning-unit
states. To keep the README compact, we display the contrast table and
only a few rows of planning-unit consistency; detailed transition
records remain available from the function itself.
linkage_contrasts(turnover, type = "high_reconfiguration", n = 2)
#>   contrast_rank        contrast_type from_solution to_solution
#> 1             1 high_reconfiguration             3           2
#> 2             2 high_reconfiguration             4           3
#>   objective_distance decision_similarity decision_distance objective_tie
#> 1          0.1729464           0.6390935         0.3609065         FALSE
#> 2          0.2565453           0.5766297         0.4233703         FALSE
#>   reconfiguration_rate changed_assignments changed_planning_units additions
#> 1             2.086811                3822                   2175      1915
#> 2             1.650275                4663                   2655      2324
#>   removals activated_planning_units deactivated_planning_units action_switches
#> 1     1907                      268                        260            1647
#> 2     2339                      316                        331            2008
#>   composition_changes from_cost to_cost delta_cost improvement_cost
#> 1                   0     23173   22765       -408              408
#> 2                   0     23980   23173       -807              807
#>   from_spatial to_spatial delta_spatial improvement_spatial
#> 1         5231       7865          2634               -2634
#> 2         3306       5231          1925               -1925

transition <- linkage_transition(
  alternatives, from = 1, to = 2, objectives = c("cost", "spatial")
)
print(transition)
#> Spatial solution transition
#> From solution: 1
#> To solution:   2
#>
#> Planning units changed: 4571 of 11109 (41.1%)
#> Activated:            168
#> Deactivated:          149
#> Action switches:      4254
#> Composition changes:  0
#>
#> Objective changes:
#> - cost: 128 (improvement -128)
#> - spatial: -14620 (improvement 14620)
#>
#> Use `$summary`, `$objectives`, `$transitions`, `$actions`, or `$state_matrix` for details.

head(selection_consistency(alternatives))
#>      pu solution_group n_solutions selected_frequency managed_frequency
#> 1     1            all           6                1.0               1.0
#> 2    10            all           6                1.0               1.0
#> 3   100            all           6                1.0               1.0
#> 4  1000            all           6                1.0               1.0
#> 5 10000            all           6                0.0               0.0
#> 6 10001            all           6                0.5               0.5
#>   unmanaged_frequency dominant_state dominant_frequency dominant_tie n_states
#> 1                 0.0            BAU          0.8333333        FALSE        2
#> 2                 0.0            BAU          0.8333333        FALSE        2
#> 3                 0.0            BAU          0.8333333        FALSE        2
#> 4                 0.0  Afforestation          0.8333333        FALSE        2
#> 5                 1.0      unmanaged          1.0000000        FALSE        1
#> 6                 0.5      unmanaged          0.5000000        FALSE        3
#>   variable   entropy normalized_entropy
#> 1     TRUE 0.4505612          0.6500224
#> 2     TRUE 0.4505612          0.6500224
#> 3     TRUE 0.4505612          0.6500224
#> 4     TRUE 0.4505612          0.6500224
#> 5    FALSE 0.0000000          0.0000000
#> 6     TRUE 1.0114043          0.9206198
A complete executable example is provided in examples/meseta_iberica.R.
The simulated
workflow introduces additional optimisation methods and diagnostics
on a smaller dataset.
The package provides several prepared examples:
| Loader | Example |
|---|---|
load_sim_multiaction() |
64 spatial cells, two features and two actions for quick examples |
load_meseta() |
The Meseta Ibérica inputs used in this README |
load_ecosystem_services() |
Planning units and four raster layers for the integrated-planning vignette |
Browse the function
reference for details of create_problem(),
add_actions(), add_effects(),
add_constraint_targets_absolute(), the
set_method_*() functions, and solve(). Tools
for inspecting alternatives are organised as frontier_*(),
selection_*(), and linkage_*().
If you find a bug or would like to suggest an improvement, please open an issue.
Cánibe Iglesias, M., Hermoso, V., Azevedo, J. C., Campos, J. C., Salgado-Rojas, J., Sil, A., & Regos, A. (2025). Integrating multiple landscape management strategies to optimise conservation under climate and planning scenarios: a case study in the Iberian Peninsula. Ecosystem Services, 74, 101742. doi:10.1016/j.ecoser.2025.101742.
Tallis, H., Fargione, J., Game, E., et al. (2021). Prioritizing actions: spatial action maps for conservation. Annals of the New York Academy of Sciences, 1505(1), 118-141. doi:10.1111/nyas.14651.
Salgado-Rojas, J., Hermoso, V., & Alvarez-Miranda, E. (2023). prioriactions: Multi-action management planning in R. Methods in Ecology and Evolution. doi:10.1111/2041-210X.14220.
Neubert, S., McGowan, J., Metcalfe, K., et al. (2025). Multiple-use spatial planning for sustainable development and conservation. Trends in Ecology & Evolution, 40(11), 1126-1142. doi:10.1016/j.tree.2025.09.007.
These binaries (installable software) and packages are in development.
They may not be fully stable and should be used with caution. We make no claims about them.
Health stats visible at Monitor.