The hardware and bandwidth for this mirror is donated by dogado GmbH, the Webhosting and Full Service-Cloud Provider. Check out our Wordpress Tutorial.
If you wish to report a bug, or if you are interested in having us mirror your free-software or open-source project, please feel free to contact us at mirror[@]dogado.de.


SITSAR brings together statistical models, information-theoretic measures and image-analysis tools for Synthetic Aperture Radar (SAR) and polarimetric SAR (PolSAR) data. It gathers the methods developed in the master’s dissertation (divergence-based classifiers) and in the PhD thesis (Shannon entropies, entropy-based segmentation and change detection, and compound Wishart models) of Jodavid A. Ferreira, supervised by Abraão D. C. Nascimento (UFPE, Brazil).
The main tools are R6 classes, and the classifiers are available as a parsnip model, so they work inside tidymodels workflows (recipes, resampling, tuning and yardstick metrics).
| Topic | Tools |
|---|---|
| Intensity models | dg0i()/pg0i()/qg0i()/rg0i(),
*gammasar(), *ggamma() |
| Matrix (PolSAR) models | dwishart_sar(),
dg0p(), dctpcw(), dcgcw() and
generators |
| R6 models (ML/EM estimation, entropy, variance) | GammaSAR, G0I,
GGammaSAR, WishartSAR,
G0Polarimetric, CompoundWishart |
| Shannon entropies | entropy_gamma(),
entropy_g0i(), entropy_ggamma(),
entropy_wishart(), entropy_g0p() |
| Images | SARImage,
sar_features(), entropy_map(),
plot_map() |
| Segmentation | EntropySegmenter (EM / SEM),
segment_sar() |
| Hypothesis tests and change detection | entropy_test(),
change_map(), change_detection_metrics() |
| Divergences and classification | divergence_gaussian(),
divergence_wishart(), distancesg0i(),
DivergenceClassifier,
divergence_classifier() |
| Accuracy | kappa_statistics() |
# From CRAN
install.packages("SITSAR")

# Development version from GitHub
# install.packages("remotes")
remotes::install_github("jodavid/SITSAR")The package ships a 150 x 150 crop of the L-band AIRSAR image of San
Francisco (SanFrancisco150) and its ground truth
(SanFrancisco150_gt).
library(SITSAR)

img <- SARImage$new(SanFrancisco150, looks = 4)
img
#> <SARImage> 150 x 150 PolSAR (3 x 3 covariance)
#>   channels: HH, HV, VV
#>   looks: 4
#>   mean HH  = 0.1735
#>   mean HV  = 0.04224
#>   mean VV  = 0.147

op <- par(mfrow = c(1, 2))
img$plot()
plot_map(SanFrancisco150_gt, main = "Ground truth",
         palette = c("#1f78b4", "#33a02c", "#e31a1c"))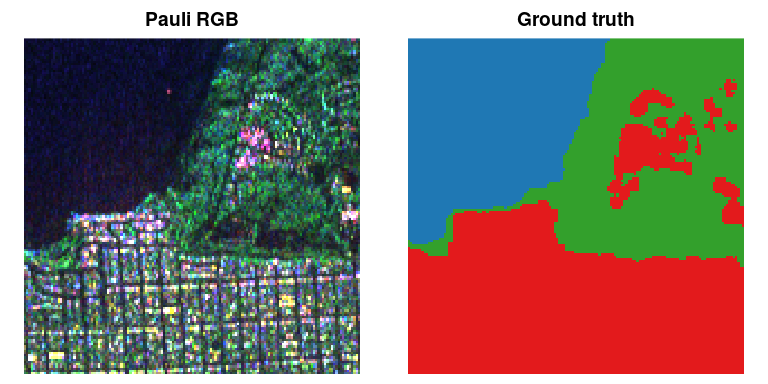
par(op)set.seed(1)
x <- rg0i(1000, alpha = -3, gamma = 2, L = 4)
fit <- G0I$new()$fit(x) # maximum likelihood (alpha, gamma and L)
fit
#> <G0I> fitted to n = 1000 observations
#> alpha = -3.95788
#> gamma = 2.80374
#> L = 3.00607
#> logLik = -835.636
#> Shannon entropy = 0.835636
fit$entropy_variance() # asymptotic variance of the entropy estimator
#> [1] 0.001158187
generics::tidy(fit)
#> # A tibble: 3 × 4
#> term estimate std.error fixed
#> <chr> <dbl> <dbl> <lgl>
#> 1 alpha -3.96 0.531 FALSE
#> 2 gamma 2.80 0.469 FALSE
#> 3 L 3.01 0.311 FALSE
# Polarimetric models
Sigma <- polsar_example_sigma("forest")
Z <- rg0p(500, alpha = -4, Sigma = Sigma, L = 4)
G0Polarimetric$new()$fit(Z, L = 4)$params$alpha
#> [1] -4.028688H <- entropy_map(img, model = "wishart", window = 7, L = 4)
set.seed(2)
seg <- EntropySegmenter$new(k = 3, method = "em")$fit(H)
op <- par(mfrow = c(1, 2))
plot_map(H, main = "Wishart entropy map")
plot_map(seg$label_map(), main = "Entropy-based segmentation",
palette = c("#1f78b4", "#33a02c", "#e31a1c"))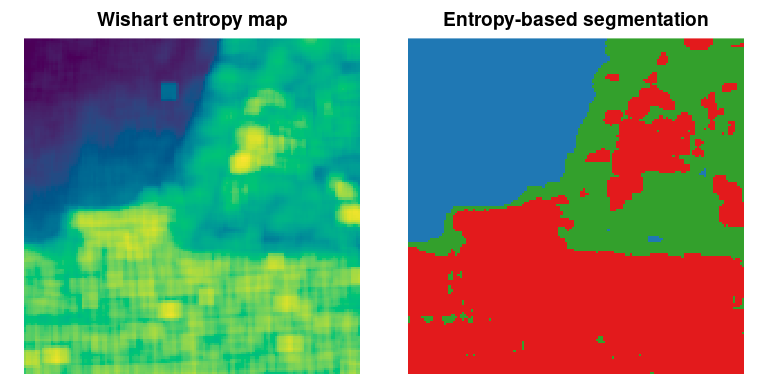
par(op)

kappa_statistics(SanFrancisco150_gt, seg$label_map(), match = TRUE)
#> # A tibble: 1 × 5
#>   kappa   variance std_error overall_accuracy     n
#>   <dbl>      <dbl>     <dbl>            <dbl> <dbl>
#> 1 0.914 0.00000566 0.00238 0.945 22500library(parsnip)
library(workflows)
library(recipes)
library(yardstick)
feats <- sar_features(img, window = 5)
feats$class <- factor(as.vector(SanFrancisco150_gt),
labels = c("ocean", "vegetation", "urban"))
set.seed(3)
train <- feats[sample(nrow(feats), 450), ]
spec <- divergence_classifier(divergence = "renyi", order = 0.9) |>
set_engine("wishart")
rec <- recipe(class ~ ., data = train) |>
update_role(row, col, new_role = "id")
wf_fit <- workflow(rec, spec) |> fit(data = train)
pred <- augment(wf_fit, feats)
accuracy(pred, truth = class, estimate = .pred_class)
#> # A tibble: 1 × 3
#> .metric .estimator .estimate
#> <chr> <chr> <dbl>
#> 1 accuracy multiclass 0.952set.seed(4)
before <- matrix(rgammasar(60 * 60, mu = 1, L = 4), 60)
after <- before
after[21:40, 21:45] <- rgammasar(500, mu = 3, L = 4)
cd <- change_map(before, after, model = "gamma", window = 5, L = 4)
cd
#> <Entropy-based change map> model: gamma | level: 0.01
#> size: 60 x 60
#> changed pixels: 611 (16.97%)
plot_map(cd$change, main = "Detected changes")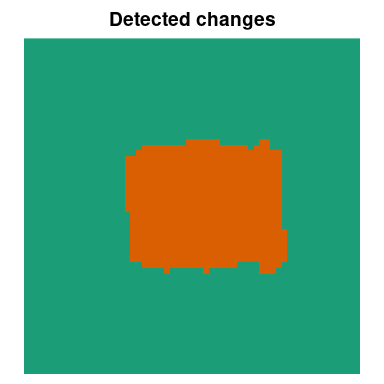
vignette("SITSAR") — getting started;vignette("tidymodels", package = "SITSAR") —
divergence-based classifiers with tidymodels;citation("SITSAR")These binaries (installable software) and packages are in development.
They may not be fully stable and should be used with caution. We make no claims about them.
Health stats visible at Monitor.